
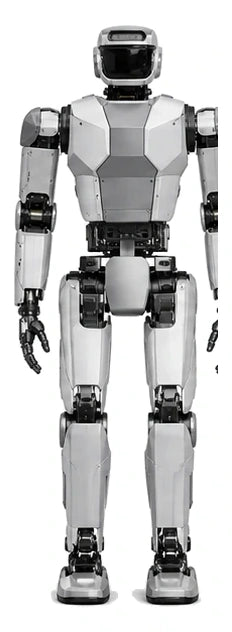
 Front view
Kawada Roboticsresearch platformhumanoid
HRP-5P specs, images, and availability
Humanoid platform in Japan's HRP research line
Images and videos
HRP-5P photo gallery and movement media
Standardized views make it easier to compare body shape, proportions, end effectors, visible hardware, and public demo evidence across robots.
Front view Side view
 Rear view
 Head and torso
 Arm detail
 Leg detail
 Arm and leg detail
Additional images
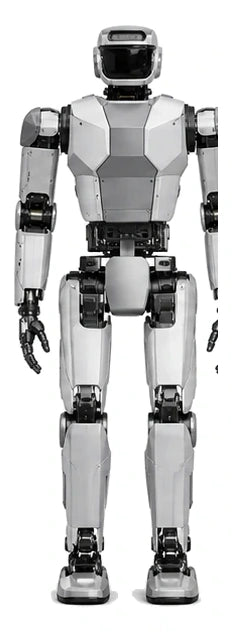 Hero Image
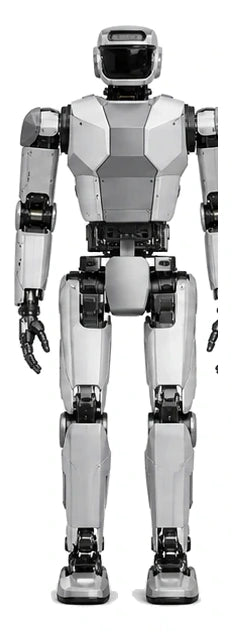 Main WebP
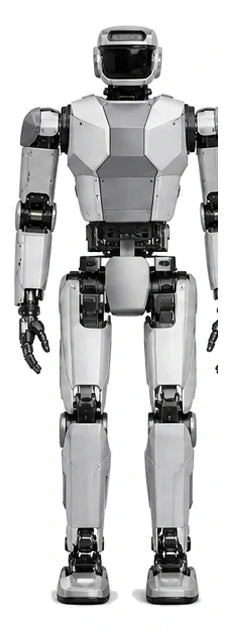 Front View
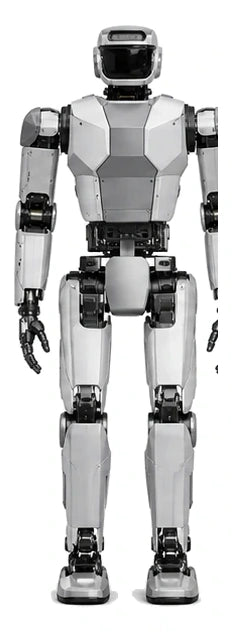 Front View
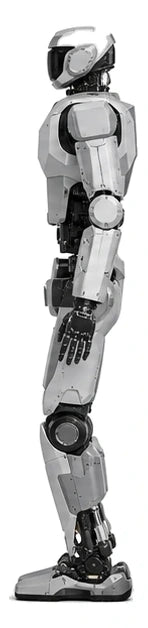 Side View
 Side View
 Side View
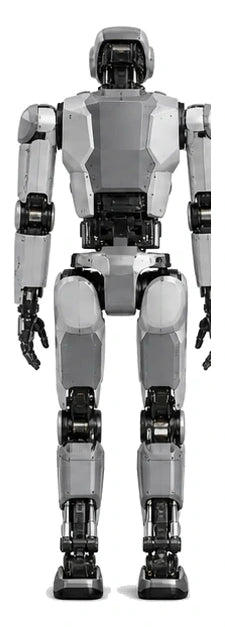 Rear/Back View
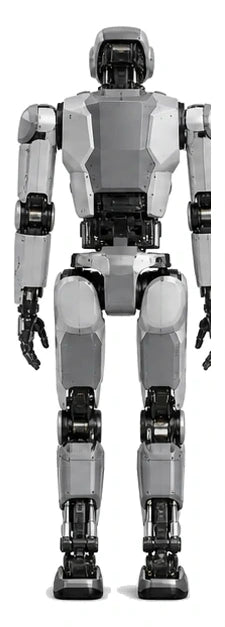 Rear/Back View
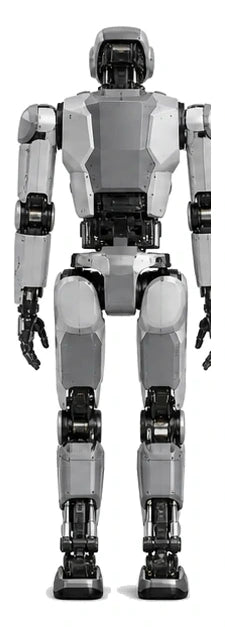 Rear/Back View
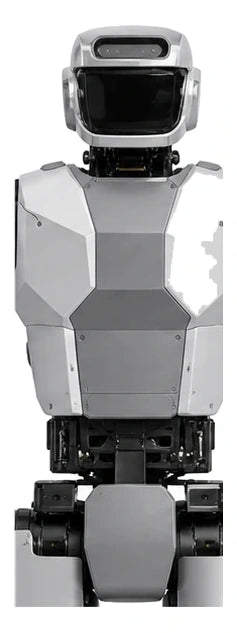 Head/Torso View
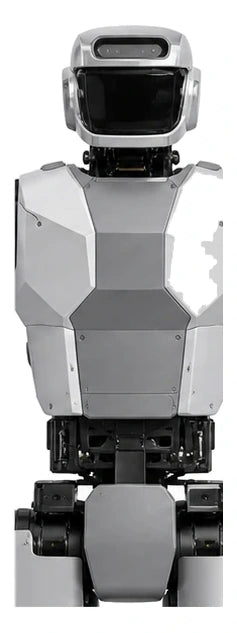 Head/Torso View
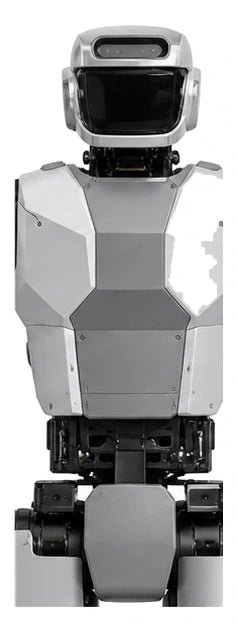 Head/Torso View
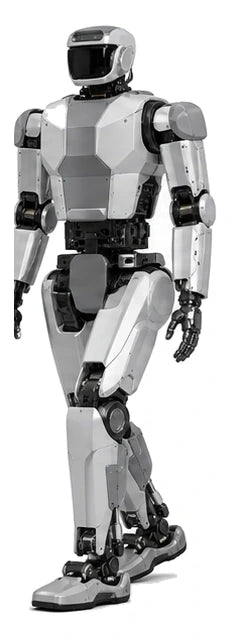 Arm + Leg View
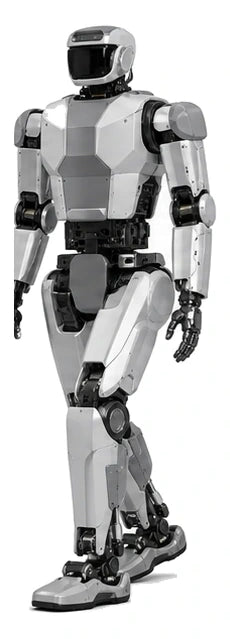 Arm + Leg View
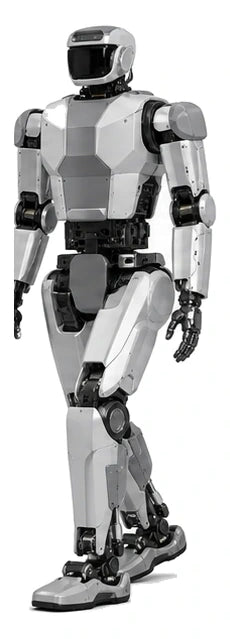 Arm + Leg View
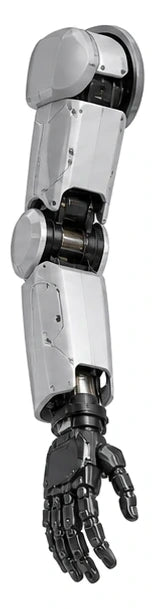 Arm View
 Arm View
Robot Intelligence Profile
Overview, buying status, and research notes
Profile coverage
Documented facts and source coverage
This humanoid profile connects reviewed reference records where available, including manufacturer pages, documentation, media, papers, patents, and community notes.
Public spec details20 items
Reference links1 sources
Images26 views
Videos0 clips
Data confidence97%
HRP-5P spec card
HRP-5P specs, price, availability and comparison
Quick answer: HRP-5P is a humanoid associated with Kawada Robotics. Based on currently available public information, its availability is research platform, and its pricing status is Not sold commercially.
This profile is designed for people comparing humanoid robots, evaluating robot buying options, checking developer suitability, or researching the state of commercial robotics. Fields without enough public support stay unconfirmed until a stronger source is attached.
What is HRP-5P?
Humanoid platform in Japan's HRP research line
Who makes it?
Kawada Robotics is the manufacturer currently connected to this profile. Use the linked manufacturer page and source cards below to verify company-level details, model lineage, and official product information.
What is it designed for?
HRP-5P is most relevant for construction, industrial research. Treat use-case claims carefully when the robot is still marked as prototype, piloting, announced, or unavailable to the public.
Availability and price
Availability: research platform. Price: Not sold commercially. Robot pricing often depends on configuration, support contract, accessories, and whether the customer is buying, leasing, or joining a pilot.
Hardware and design
Height: 182 cm (1820 mm); Weight: 101 kg; Total degrees of freedom: 37; Neck DOF: 2; Hand DOF: 2 per hand
Mobility
Walking: Legged walking mobility
Hands, manipulation and payload
Payload: Can handle gypsum boards approx. 11 kg or plywood panels approx. 13 kg with both arms
Battery and charging
Battery chemistry, charging method, and runtime are not fully documented in the public data yet. Runtime should not be assumed beyond the fields shown in the specification table.
AI, software and developer support
SDK: research stack; Choreonoid simulation/regression environment reported; ROS: not publicly specified
Strengths
- 1 linked source records support verification.
- 26 approved image assets help compare visible design and proportions.
- Height is listed as 182 cm (1820 mm).
- Payload is listed as Can handle gypsum boards approx. 11 kg or plywood panels approx. 13 kg with both arms.
- Degrees of freedom are listed as 37.
Limitations and uncertainties
- Runtime is not fully documented in the public data.
- Robot specifications can change quickly as manufacturers revise hardware, software, and deployment programs.
Best use cases
- construction
- industrial research
Not ideal for
- Buyers who need guaranteed availability without confirming directly with the manufacturer.
- Procurement decisions that require independently verified pricing, warranty, and deployment support.
- Applications where missing safety, runtime, payload, or autonomy data cannot be tolerated.
Similar robots and comparisons
Compare HRP-5P against nearby robots to understand maturity, cost, availability, hardware tradeoffs, and ecosystem differences.
FAQ
What is HRP-5P?
HRP-5P is a humanoid associated with Kawada Robotics. FIRGELLI Robots tracks its public specifications, media, source links, availability status, and comparison data in one profile.
Who makes HRP-5P?
HRP-5P is listed with Kawada Robotics. Use the manufacturer profile and source links on this page to verify company details before making buying or research decisions.
Is HRP-5P available to buy?
Current availability status: research platform. If the robot is marked as a prototype, pilot, announced, or not publicly sold, treat pricing and delivery claims as preliminary.
How much does HRP-5P cost?
Pricing status: Not sold commercially. Robot prices often vary by configuration, support contract, deployment type, and customer type.
What are the main HRP-5P specifications?
Headline specs include height 182 cm (1820 mm), runtime Not publicly verified, payload Can handle gypsum boards approx. 11 kg or plywood panels approx. 13 kg with both arms, and degrees of freedom 37.
What is HRP-5P best used for?
HRP-5P is most useful to evaluate in the context of construction; industrial research.
Specifications
HRP-5P specifications
Specs are grouped into practical sections with plain-language values so readers can quickly compare the robot.
Identity 7 public details
Robot NameHRP-5P
ManufacturerKawada Robotics
Country of OriginJapan
StatusAIST research prototype / R&D platform
AvailabilityResearch platform
MarketResearch, Industrial research
Official product pageOpen official product page
Pricing 1 public detail
MSRPNot sold commercially
Physical Dimensions 2 public details
Height182 cm (1820 mm)
Weight101 kg
Mobility 1 public detail
WalkingLegged walking mobility
Degrees of Freedom 5 public details
Total degrees of freedom37
Neck DOF2
Hand DOF2 per hand
Torso DOF3 waist DOF
Actuators37 actuators minimum (estimated from total DOF)
Payload 1 public detail
PayloadCan handle gypsum boards approx. 11 kg or plywood panels approx. 13 kg with both arms
Vision 1 public detail
Camera ResolutionHead-mounted 3D environment measurement sensors; object recognition CNN
Software 2 public details
SDKresearch stack; Choreonoid simulation/regression environment reported
ROSnot publicly specified
Sources
Source links, manuals, papers, and further reading
Use these links to verify claims, inspect manufacturer pages, or continue deeper technical research.
Primary and supporting sources
Official pages, manufacturer pages, launch pages, and supporting references.